MIT researchers build swimming robot driven by living muscle
Light-controlled muscle cells power two fins, allowing the thin device to steer through an underwater maze.
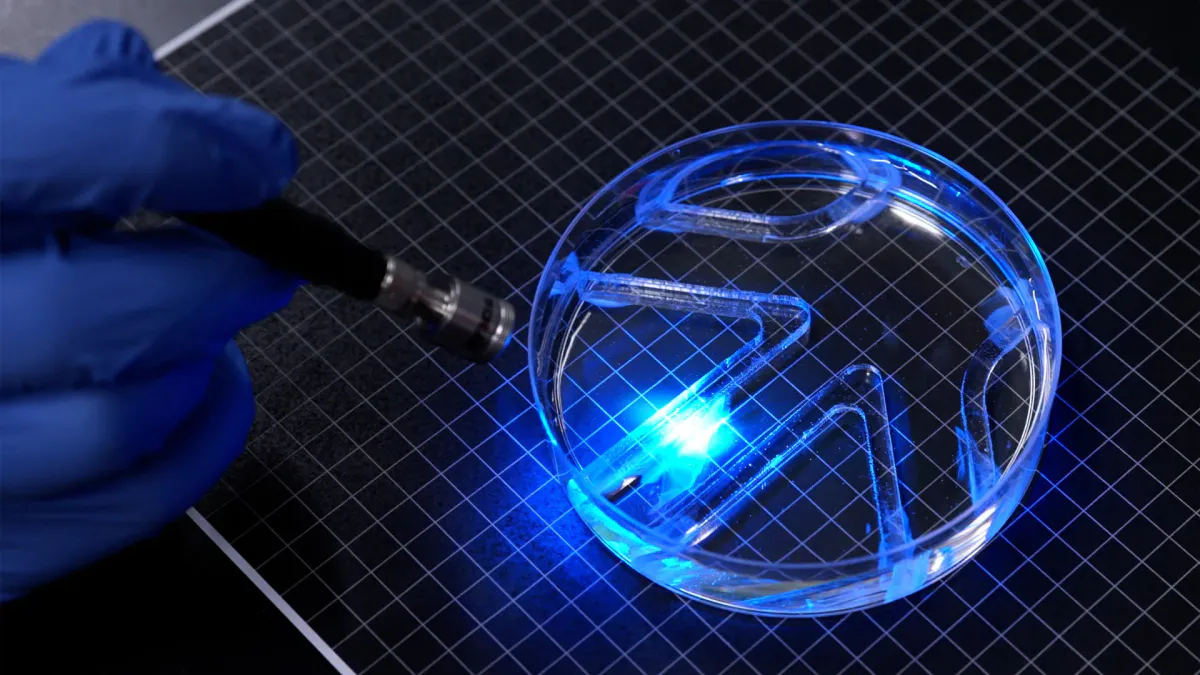
MIT researchers have demonstrated a small swimming robot propelled by living muscle, reporting that it navigated an underwater maze and reached a maximum speed of approximately four body lengths per minute. The work appears in Advanced Functional Materials.
The device has a flexible gel body with dimensions similar to a stick of gum. Genetically modified muscle cells covering its two fins contract in response to light. Illuminating the fins separately, and varying the frequency of illumination, lets researchers adjust the robot’s direction and speed.
To develop a support that could withstand the contractions, the team tested different gel compositions, stiffness levels and surface patterns. They replaced the softer material fibrin with gelatin methacrylate, or GelMA. Firmer gels and grooves with square profiles helped the cells align and produce stronger contractions.
A gel thickness of approximately half a millimeter provided support without excessive weight. Before assembling the swimmer, the researchers strengthened the muscle tissue by repeatedly stimulating it with light pulses. They then tested the robot in a water-filled petri dish, manually moving a light source to guide it around obstacles.
Study author Ritu Raman, an MIT associate professor of mechanical engineering, said the team plans to improve the body design for faster swimming. She suggested that such devices could eventually monitor aquatic environments. The Office of Naval Research partly funded the research.